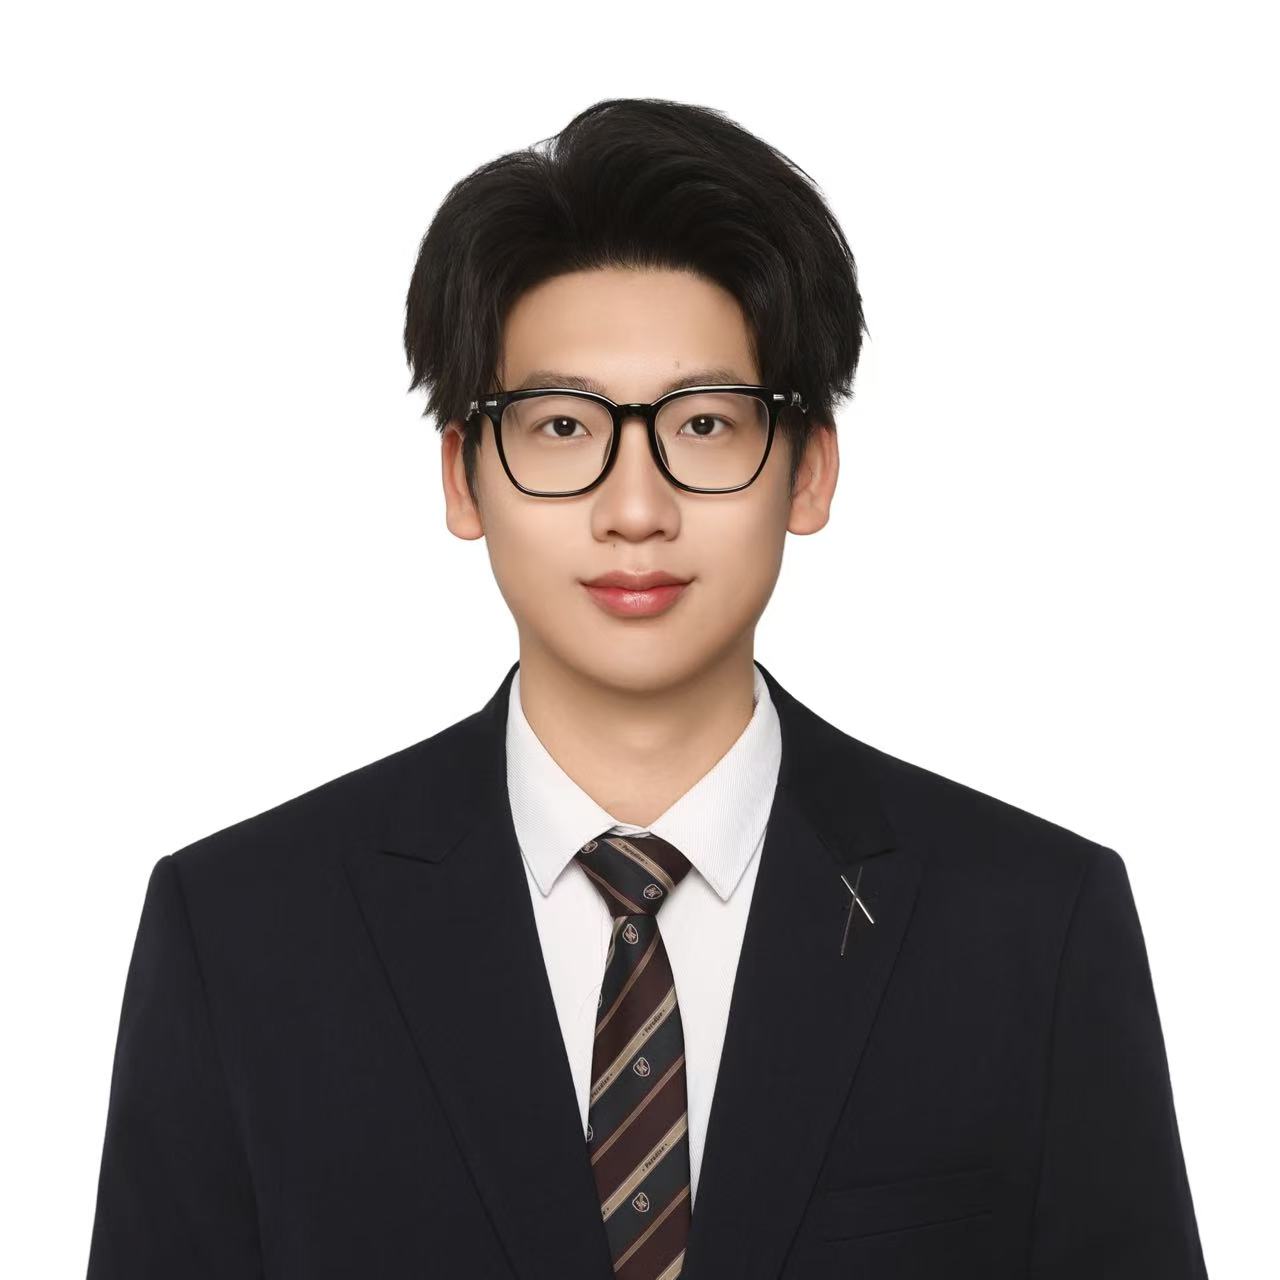
I am currently pursuing my Ph.D. in Robotics and Autonomous Systems at The Hong Kong University of Science and Technology (Guangzhou) (HKUST-GZ), under the supervision of Prof. Renjing Xu. Prior to joining HKUST-GZ, I received my B.Eng. in Artificial Intelligence from South China Agricultural University (SCAU) in 2024. I also serve as an AI Algorithm Engineer at CLAI-LAB, where I am leading a humanoid robot R&D team and a multi-agent collaboration research team.
My research interests span Humanoid Robotics, Locomotion & Parkour, Whole Body Control, Motion Tracking, Vision-Language-Action (VLA), and Computer Vision. I am passionate about building embodied intelligent systems that can perceive, reason, and act in the physical world. I have published several papers in top-tier agricultural AI journals.
I won 3rd place at the 2025 World Humanoid Robot Games (Field Events) and have been recognized with the Annual Outstanding Employee (Innovation Award, 2024) and multiple national/provincial competition awards.
🔥 News
- 2026-now: 🎉 Started my PhD journey at HKUST(GZ) in Robotics and Autonomous Systems!
- 2025.08: 🏆 Won 3rd place at the 2025 World Humanoid Robot Games (martial arts)!
- 2025.10: 🥇 Our team won Champion at the Zayed Charity Run Robot Marathon!
- 2025.09: 🏅 Our team won Outstanding Award at the “巧手点天工” Aviation Dexterous Hand Elite Competition!
- 2024.12: 📄 IA-YOLO accepted by Agriculture (JCR Q1 / SCI Q2, IF=3.3) as Corresponding Author!
- 2024.06: 📄 Taoism-Net published in Agronomy (JCR Q1 / SCI Q2, IF=3.7) as First Author!
- 2024.03: 🚀 Started as AI Algorithm Engineer, leading humanoid robot R&D and multi-agent research projects.
- 2024.12: 🏆 Awarded Annual Outstanding Employee (Innovation Award) at my company.
📝 Publications
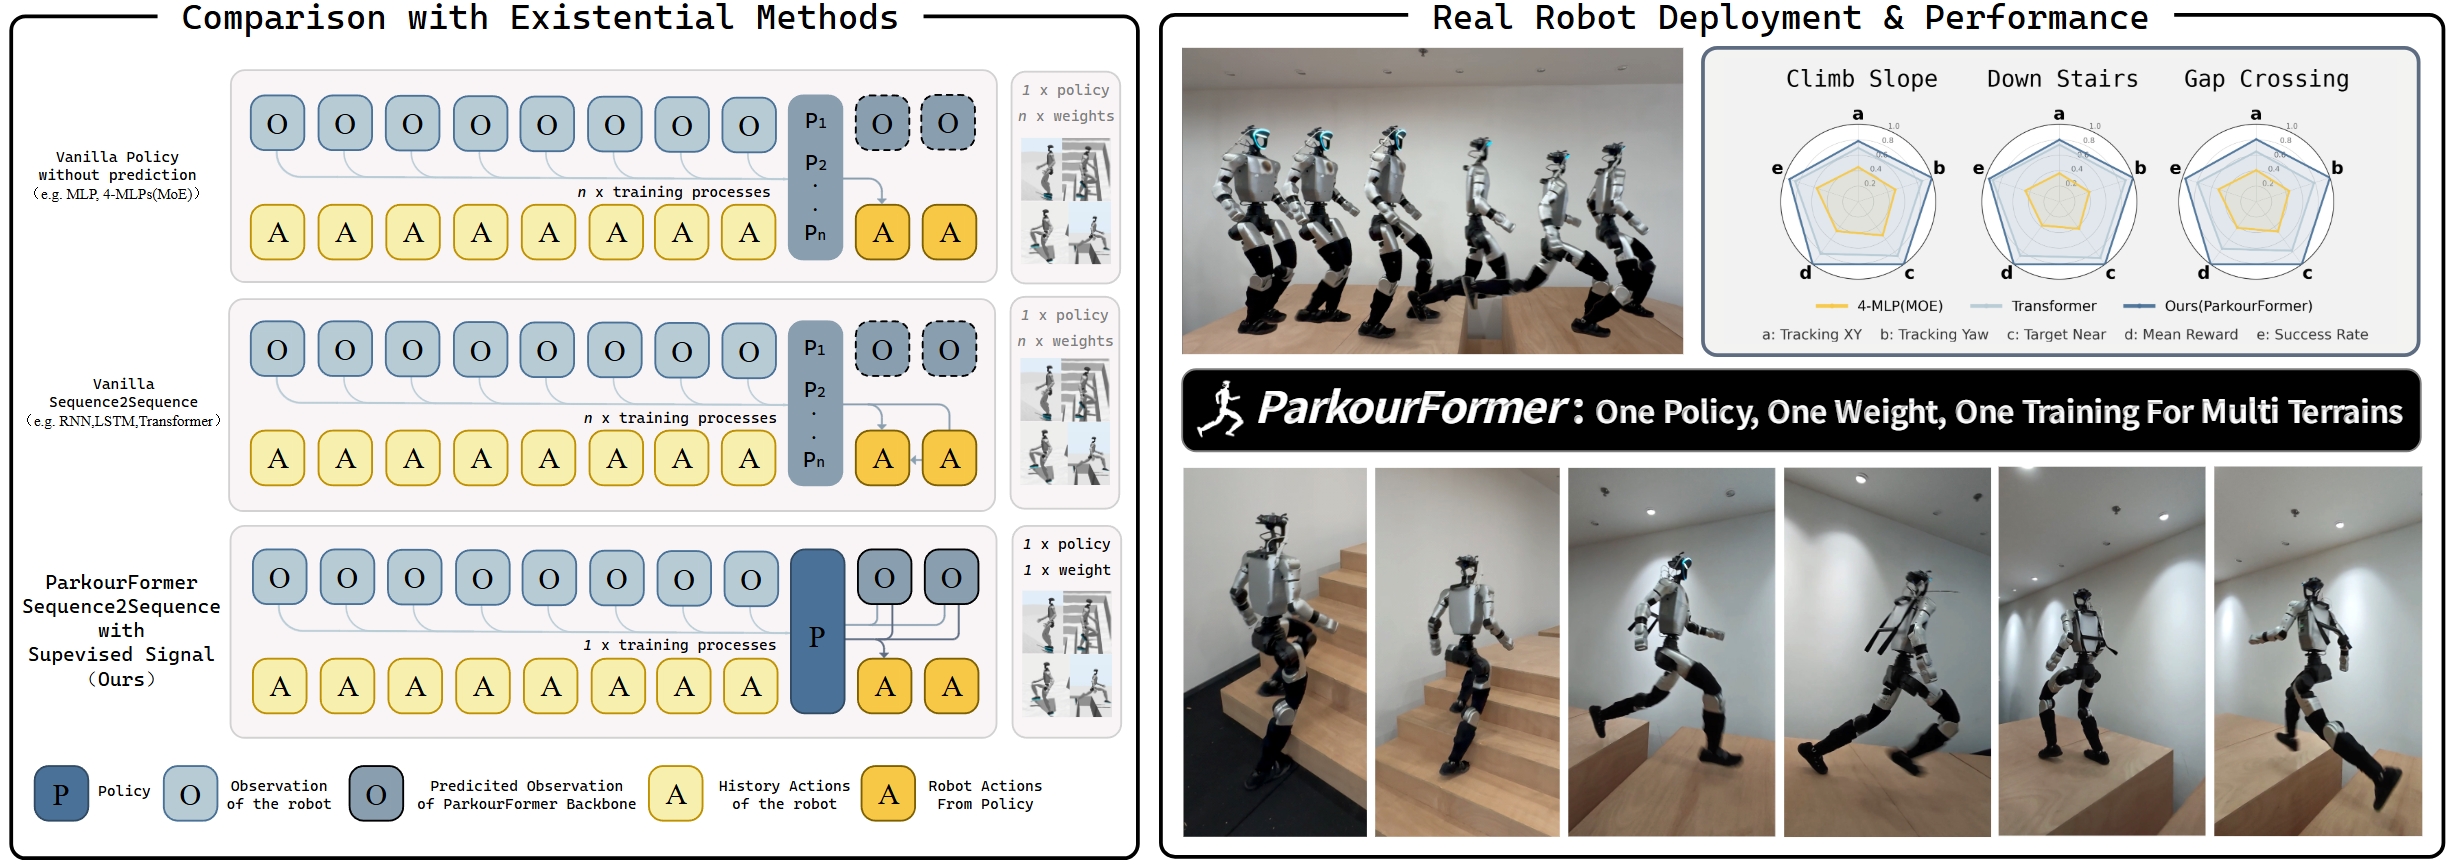
ParkourFormer: Integrating Predictive Supervision and Sequence Modeling into Parkour Locomotion
Yanheng Mai, et al.
In Submission
DOI First Author
- We introduce a novel “now → past → future” paradigm, where the current state queries historical trajectories to explicitly predict future outcomes, demonstrating strong adaptability to various challenging environments.
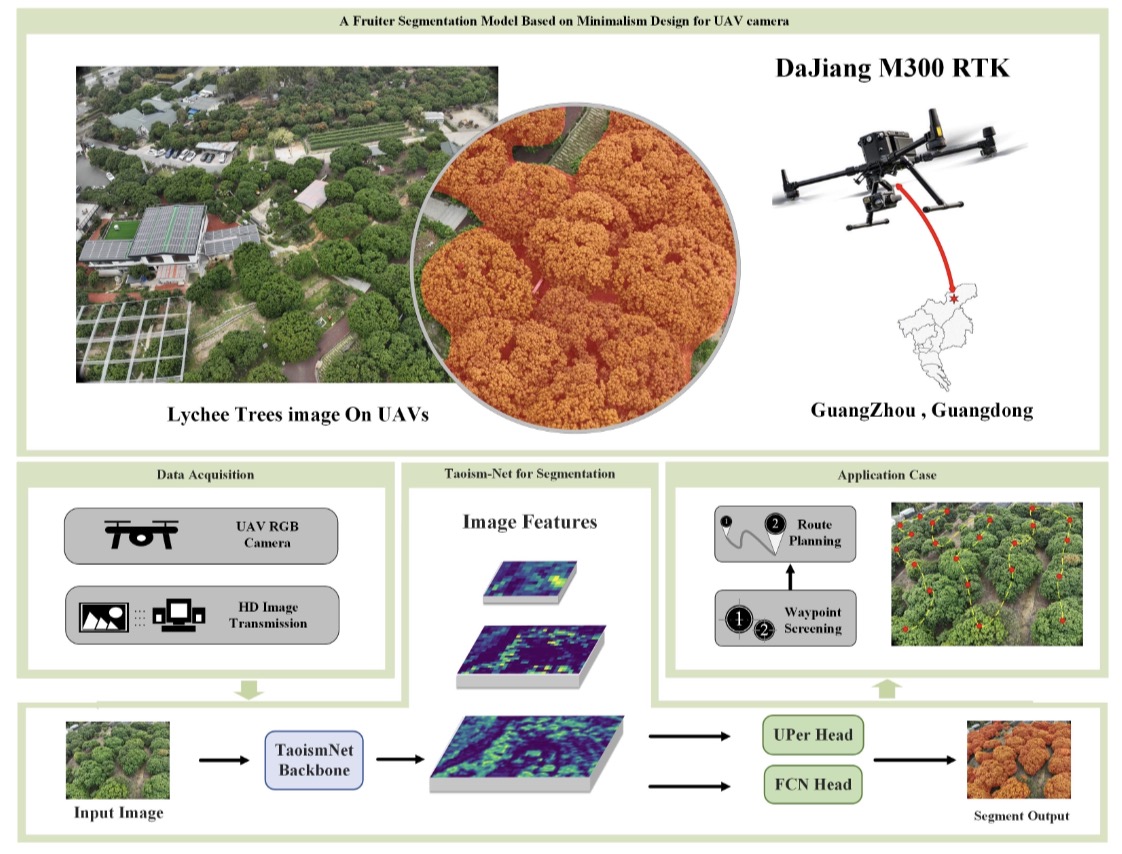
Taoism-Net: A Fruiter Segmentation Model Based on Minimalism Design for UAV Camera
Yanheng Mai, et al.
Agronomy, 2024, 14(6), 1155. JCR Q1 / SCI Q2, IF=3.7
DOI First Author
- Proposed a minimalist-design segmentation model (Taoism-Net) for drone-view fruit detection, achieving state-of-the-art accuracy with significantly reduced model complexity.
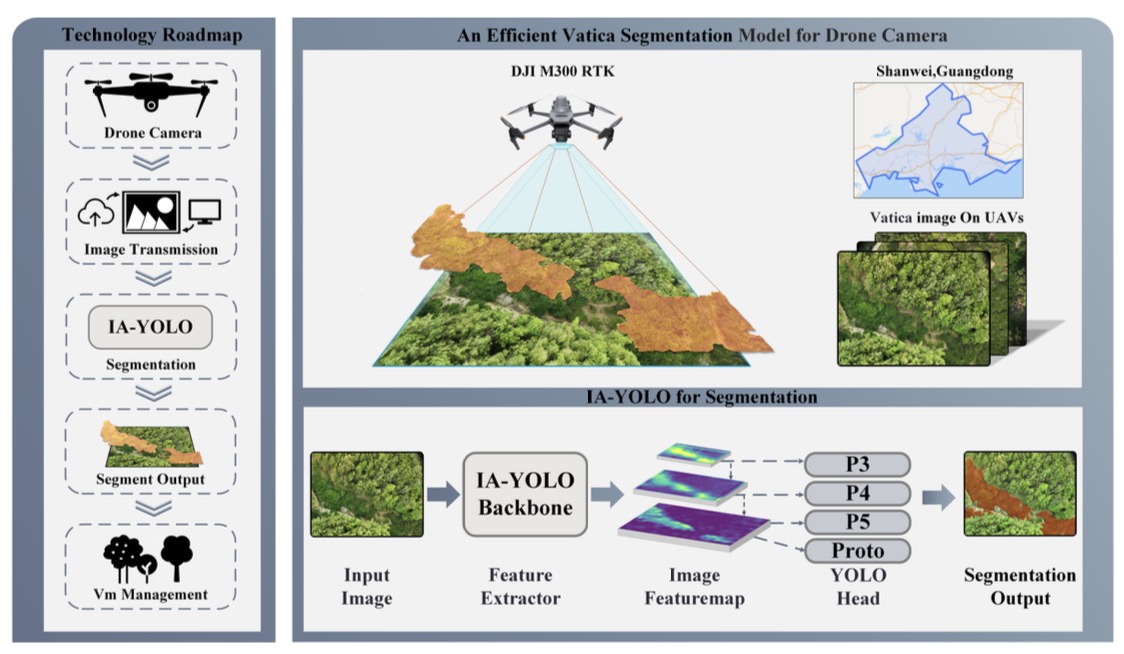
IA-YOLO: An Efficient Vatica Segmentation Model Based on Inverted Attention Block for Drone Camera
…, Yanheng Mai (Corresponding Author)
Agriculture, 2024, 14(12), 2252. JCR Q1 / SCI Q2, IF=3.3
DOI Corresponding Author
- Designed an inverted attention mechanism integrated into YOLO for efficient semantic segmentation on UAV imagery in precision agriculture.
- 基于CNNs和Transformer混合的茶田路径分割模型 — 中国农机化学报(Journal of Chinese Agricultural Mechanization) (北大核心), 2026, IF=1.6. First Author. DOI: 10.13733/j.jcam.issn.2095-5553.2026.02.029
🎖 Honors and Awards
- 2025 🥉 3rd Place — 2025 World Humanoid Robot Games (世界人形机器人运动会), Field Events
- 2025 🏆 Champion — Zayed Charity Run Robot Marathon (扎耶德慈善跑机器人马拉松)
- 2025 🏅 Outstanding Team — “巧手点天工·航空灵巧手菁英赛”
- 2024 🌟 Annual Outstanding Employee (Innovation Award) — CLAI-LAB, Suzhou Chenling Optics Co., Ltd
- 2023 Second-class Scholarship — South China Agricultural University
- 2023 Provincial Bronze — China “互联网+” Innovation & Entrepreneurship Competition
- 2022 Provincial Bronze — China “互联网+” Innovation & Entrepreneurship Competition
- 2022 Provincial Second Prize — Guangdong “高教社杯” Mathematical Modeling Competition
- 2022 Second Prize — Asia-Pacific Mathematical Modeling Competition (APMCM)
- 2022 Provincial First Prize — Guangdong Agricultural Machinery Electronics Competition
- 2021 School-level First Prize — “Intel” Cup AI Competition
📖 Educations
- 2026 - present Ph.D. in Robotics and Autonomous Systems — The Hong Kong University of Science and Technology (Guangzhou), HKUST-GZ
- 2020 - 2024 B.Eng. in Artificial Intelligence — South China Agricultural University (SCAU)
💻 Work Experience & Projects
- 2024.03 - present AI Algorithm Engineer — CLAI-LAB (Computer Vision, Embodied AI & Robotics Direction)
- Full-sized Humanoid Robot R&D : Led full-stack development of a 170cm humanoid robot; designed layered OS architecture (HAL/Connect/MC/HDS) on ROS2; implemented EtherCAT/USB HAL, FDCAN 1kHz multi-motor real-time control (STM32H7/G4), trajectory planning, inverse kinematics; built sim-to-real pipeline (MjLab/Isaac Lab) with AMP for humanoid gait; developed VLA end-to-end model via LLM+MCP.
- AI Training Platform Backend: Developed full training pipeline (detection/classification/segmentation/anomaly detection); implemented core operator encryption, weight file encryption, C#/C++ interfaces; filed invention patents and utility model patents.
- 2022.01 - 2022.05 Research Intern — Industrial Technology Research Dept., Hitachi China Ltd., Guangzhou Branch
- Deployed light cnn detection network on a 6-axis robot arm; processed Intel RealSense RGB + 3D point cloud data for workspace plane interpolation to assist robot decision-making.
- 2020.12 - 2023.06 President — SCAU Artificial Intelligence Association
🤖 PhD Research (HKUST-GZ)
Direction 1 — Locomotion & HSI (Human-Scene Interaction)
Direction 2 — Motion Tracking & Whole Body Control & HOI
Development — Full-Size 170cm Humanoid Robot